Learning Ansible

Week 1 - 27/12/2024


 Ansible is an open-source automation tool used for configuration management, application deployment, and task automation. It simplifies complex IT tasks by automating repetitive processes, making it easier to manage large-scale systems.

Key Features of Ansible

  • Agentless: Unlike other automation tools, Ansible does not require any agent software to be installed on the managed nodes. It uses SSH for communication, making it lightweight and easy to set up.

  • Declarative Language: Ansible uses a simple, human-readable language called YAML (Yet Another Markup Language) to define automation tasks. This makes it accessible to both developers and system administrators.

  • Idempotency: Ansible ensures that tasks are idempotent, meaning they can be run multiple times without changing the system's state if it is already in the desired state.

  • Extensible: Ansible has a modular architecture, allowing users to extend its functionality with custom modules, plugins, and roles.

Use Cases

  • Configuration Management: Ansible can manage the configuration of servers, ensuring they are set up consistently and correctly.

  • Application Deployment: Automate the deployment of applications across multiple servers, reducing the risk of human error.

  • Orchestration: Coordinate complex workflows and processes across different systems and environments.

  • Provisioning: Set up and configure new servers and infrastructure components.

Getting Started with Ansible

  1. Install Ansible: You can install Ansible using package managers like pip, apt, or yum. For example, to install Ansible using pip, run:

    bash
    pip install ansible
    
  2. Create an Inventory File: An inventory file lists the hosts and groups of hosts that Ansible will manage. Here's an example of a simple inventory file:

    ini
    [webservers]
    web1.example.com
    web2.example.com
    
    [dbservers]
    db1.example.com
    db2.example.com
    
  3. Write a Playbook: A playbook is a YAML file that defines the tasks Ansible will perform on the managed hosts. Here's an example of a basic playbook:

    yaml
    ---
    - name: Install and configure web server
      hosts: webservers
      become: yes
      tasks:
        - name: Install Apache
          apt:
            name: apache2
            state: present
    
        - name: Start Apache service
          service:
            name: apache2
            state: started
            enabled: yes
    
  4. Run the Playbook: Use the ansible-playbook command to run the playbook:

    bash
    ansible-playbook -i inventory playbook.yml
    

Benefits of Using Ansible

  • Simplicity: Ansible's straightforward syntax and agentless architecture make it easy to learn and use.

  • Scalability: Ansible can manage thousands of nodes efficiently, making it suitable for large-scale environments.

  • Flexibility: Ansible can be used for a wide range of automation tasks, from simple configuration management to complex orchestration

Why Use Ansible Rather than Jenkins 

  1. Configuration Management: Ansible excels in configuration management, automation, and orchestration, while Jenkins is primarily a CI/CD tool.

  1. Agentless Architecture: Ansible operates without the need for agents on target machines, simplifying setup and reducing overhead.

  2. Ease of Use: Ansible uses a simple, human-readable YAML syntax, making it easier to write and understand automation scripts.

  3. Idempotency: Ansible ensures tasks are idempotent, maintaining consistency in your infrastructure.

  4. Integration: Ansible integrates well with a wide range of tools and platforms, focusing on infrastructure management and automation.

  5. Declarative Approach: Ansible follows a declarative approach, defining the desired state, while Jenkins follows an imperative approach, defining the steps to be executed


    As I use Jenkins for Work, it was a refreshing to learn Ansible for Deployments.


Week 2 - 27/12/2024


Learning NodeJS and moving into DENO


What is

  • Runtime Environment: is built on Chrome's V8 JavaScript engine, enabling you to run JavaScript code outside of a web browser.

  • Event-Driven: It uses an event-driven, non-blocking I/O model, making it efficient and suitable for real-time applications.

  • Single-Threaded: Despite being single-threaded, can handle many connections simultaneously thanks to its asynchronous nature.

Key Features

  • NPM (Node Package Manager): A vast library of open-source packages that you can use to extend the functionality of your applications.

  • Asynchronous Programming: uses callbacks, promises, and async/await to handle asynchronous operations.

  • Modules: has a module system that allows you to organize your code into reusable components.

Use Cases

  • Web Servers: is commonly used to build web servers and APIs.

  • Real-Time Applications: Ideal for applications that require real-time communication, such as chat apps and online gaming.

  • Microservices: is well-suited for building microservices due to its lightweight and modular nature.

Getting Started

  1. Install : Download and install from the .

  2. Create a Project: Initialize a new project using npm init and create a package.json file.

  3. Write Your First Script: Create a simple JavaScript file, such as app.js, and write your first code.

Example Code

Here's a simple example of a server:

javascript
const http = require('http');

const server = http.createServer((req, res) => {
    res.statusCode = 200;
    res.setHeader('Content-Type', 'text/plain');
    res.end('Hello, World!\n');
});

const port = 3000;
server.listen(port, () => {
    console.log(`Server running at http://localhost:${port}/`);
});

This code creates a basic HTTP server that listens on port 3000 and responds with "Hello, World!" when accessed


Using Deno for a NodeJS replacement,

Deno is a modern runtime for JavaScript and TypeScript, created by Ryan Dahl, the original developer of It was designed to address some of the shortcomings of and to provide a more secure and efficient environment for running JavaScript and TypeScript code. Here are some advantages of Deno over Node.js:

  1. Security: Deno has a secure-by-default approach. It runs code in a sandboxed environment and requires explicit permissions for file system access, network access, and environment variables. This reduces the risk of security vulnerabilities.

  2. TypeScript Support: Deno has built-in support for TypeScript, allowing you to write and run TypeScript code without the need for additional tools or configuration. This makes it easier to work with TypeScript out of the box.

  3. Simplified Dependency Management: Deno uses URL-based imports for dependencies, eliminating the need for a separate package manager like npm. This simplifies dependency management and reduces the risk of dependency-related issues.

  4. Standard Library: Deno comes with a standard library that is audited and maintained by the Deno team. This ensures a consistent and reliable set of APIs for common tasks, reducing the need for third-party libraries.

  5. Modern Features: Deno leverages modern JavaScript features and web standards, making it more aligned with current web development practices. It also includes built-in development tooling, such as a linter, formatter, and test runner.

  6. Single Executable: Deno is distributed as a single executable file, making it easy to install and use without the need for additional setup or configuration.

While Deno offers several advantages, it's important to consider your specific use case and requirements when choosing between Deno and has a mature ecosystem, extensive community support, and a vast library of packages, which can be beneficial for many projects.


Getting Deno Working

Getting Started with Deno

  1. Installation:

    • Windows: Use the PowerShell command:

      sh
      iwr https://deno.land/x/install/install.ps1 -useb | iex
      
    • macOS/Linux: Use the shell command:

      sh
      curl -fsSL https://deno.land/x/install/install.sh | sh
      
  2. Running a Script:

    • Create a simple TypeScript file, hello.ts:

      ts
      console.log("Hello, Deno!");
      
    • Run the script using Deno:

      sh
      deno run hello.ts
      
  3. Permissions:

    • Deno is secure by default. To allow network access, use the --allow-net flag:

      sh
      deno run --allow-net server.ts
      
  4. Importing Modules:

    • Deno uses URL-based imports. For example:

      ts
      import { serve } from "https://deno.land/std@0.95.0/http/server.ts";
      
  5. Standard Library:

    • Deno comes with a standard library that you can use without additional dependencies. Check out the for more information.

  6. Development Tools:

    • Deno includes built-in tools like a linter, formatter, and test runner. You can use them as follows:

      sh
      deno lint
      deno fmt
      deno test
      

Deno offers a secure, modern, and efficient environment for JavaScript and TypeScript development.


Setting Up Pip for Python 3 on Ubuntu 24.04 and Above .

Setting Up PIP for Python 3+ on Ubuntu 24 and Above Using pip.conf

Setting Up PIP for Python 3+ on Ubuntu 24 and Above Using pip.conf

Introduction

This guide will walk you through the steps to get PIP install commands working for Python 3+ on Ubuntu 24 and above, using the pip.conf configuration file. In this the Pip Configuration is created because newer versions dont allow PIP packages to be installed from anysite, but the APT repo accepted libraries only

Step 1: Install Python 3 and PIP

  1. Update System Packages:
    sudo apt update
    sudo apt upgrade
  2. Install Python 3 (if not already installed):
    sudo apt install python3
  3. Install PIP for Python 3:
    sudo apt install python3-pip
  4. Verify PIP Installation:
    pip3 --version

Step 2: Configure pip.conf

  1. Create or Edit pip.conf:

    Create the pip.conf file in the appropriate directory. For user-specific configuration, create it in ~/.config/pip/. For global configuration, create it in /etc/pip/.

  2. Add Configuration Settings:

    Open the pip.conf file in a text editor and add the following settings:

    [global]
    break-system-packages = true
    

Step 3: Using PIP with the Configuration

  1. Install a Python Package:
    pip3 install <package-name>
  2. Upgrade a Python Package:
    pip3 install --upgrade <package-name>
  3. Uninstall a Python Package:
    pip3 uninstall <package-name>

Conclusion

By following these steps, you can ensure that PIP install commands work seamlessly for Python 3+ on Ubuntu 24 and above, using the pip.conf configuration file. This setup will help you manage Python packages efficiently and avoid common issues related to package installations.

Feel free to reach out if you need any further assistance! 🚀

Let's talk about RS485

RS-485 Communication

Let's talk about RS-485

What is RS485?

RS485 is a standard for serial communication that allows multiple devices to communicate over a single pair of wires. It's used in industrial environments due to its robustness and ability to cover long distances.

Basic Concepts

  • Differential Signaling: RS485 uses differential signaling, which means it sends data as the difference between two voltages on a pair of wires (A and B). This helps in reducing noise and allows communication over long distances (up to 1.2 km or about 4000 feet).
  • Multi-Device Communication: Up to 32 devices can be connected on a single RS485 bus.
  • Half-Duplex: Communication is typically half-duplex, meaning devices take turns sending and receiving data on the same pair of wires.

Operation

  1. Data Transmission:
    • When a device wants to send data, it generates a differential voltage (e.g., A = +5V and B = 0V for a binary '1', A = 0V and B = +5V for a binary '0').
    • This voltage difference is transmitted over the twisted pair of wires.
  2. Data Reception:
    • The receiving device detects the differential voltage and interprets it back into binary data.
    • This method helps in rejecting common-mode noise because the noise affects both wires equally, and the differential receiver can cancel it out.

Required Electronics

  1. RS485 Transceiver:
    • This IC converts TTL (Transistor-Transistor Logic) level signals from a microcontroller or other logic device to RS485 differential signals.
    • Popular transceivers include MAX485, SN75176, and ADM485.
  2. Microcontroller:
    • A microcontroller or microprocessor to handle the data you want to send or receive. This could be an Arduino, Raspberry Pi, or any other MCU.
  3. Termination Resistor:
    • To prevent signal reflections, a termination resistor (typically 120 ohms) is placed at both ends of the communication line.
  4. Pull-up/Pull-down Resistors:
    • These resistors ensure the line remains in a known state when no device is driving the bus, preventing floating inputs.

Theories Behind RS485

  1. Differential Signaling:
    • By sending the same signal as a positive voltage on one wire and as a negative voltage on another wire, RS485 can effectively cancel out noise picked up along the transmission line.
  2. Common-Mode Rejection:
    • This technique ensures that noise which affects both wires equally does not impact the signal integrity.
  3. Multipoint Communication:
    • RS485 supports multipoint communication, meaning multiple devices can share the same bus without interference, provided only one device transmits at a time.

Steps to Implement RS485 Communication

  1. Set Up the Hardware:
    • Connect the RS485 transceiver to your microcontroller.
    • Connect the A and B lines of the transceiver to the A and B lines of other RS485 devices on the bus.
    • Place a 120-ohm termination resistor at both ends of the RS485 bus.
  2. Initialize the Microcontroller:
    • Configure the UART (Universal Asynchronous Receiver/Transmitter) on your microcontroller to match the baud rate, parity, and stop bits of the RS485 network.
  3. Write Communication Code:
    • Use the UART interface of your microcontroller to send and receive data.
    • Ensure proper timing and control so only one device transmits at any time.
  4. Test the Communication:
    • Use a simple protocol to send and receive messages between devices.
    • Verify data integrity and check for any communication issues like collisions or noise interference.

Example

For an Arduino with a MAX485 transceiver:

  • Connect RO (Receiver Output) to Arduino RX.
  • Connect DI (Driver Input) to Arduino TX.
  • Connect DE (Driver Enable) and RE (Receiver Enable) to a digital pin (e.g., pin 2) to control transmission and reception.

Sample Arduino Code:


#define DE_RE 2

void setup() {
  pinMode(DE_RE, OUTPUT);
  digitalWrite(DE_RE, LOW); // Enable receiver
  Serial.begin(9600);
}

void loop() {
  // Send data
  digitalWrite(DE_RE, HIGH); // Enable transmitter
  Serial.write("Hello RS485");
  delay(100); // Wait to ensure data is sent
  digitalWrite(DE_RE, LOW); // Enable receiver

  // Receive data
  if (Serial.available()) {
    String received = Serial.readString();
    Serial.println("Received: " + received);
  }

  delay(1000); // Wait before next transmission
}
  

This code switches between sending and receiving modes, ensuring no conflict on the RS485 bus.

By understanding these basics, you can effectively design and implement RS485 communication for your project.

SLIR Projects - Small Projects with big theory

 SLIR - Sri Lanka Institute of Robotics - Advanced Robotics Course Projects 


Manipulating a GPIO in a PIC MC
Controlling a LCD using a PIC microcontroller

Connecting a Stepper Motor to Motor Driver
Connecting Motor Driver to arduino 
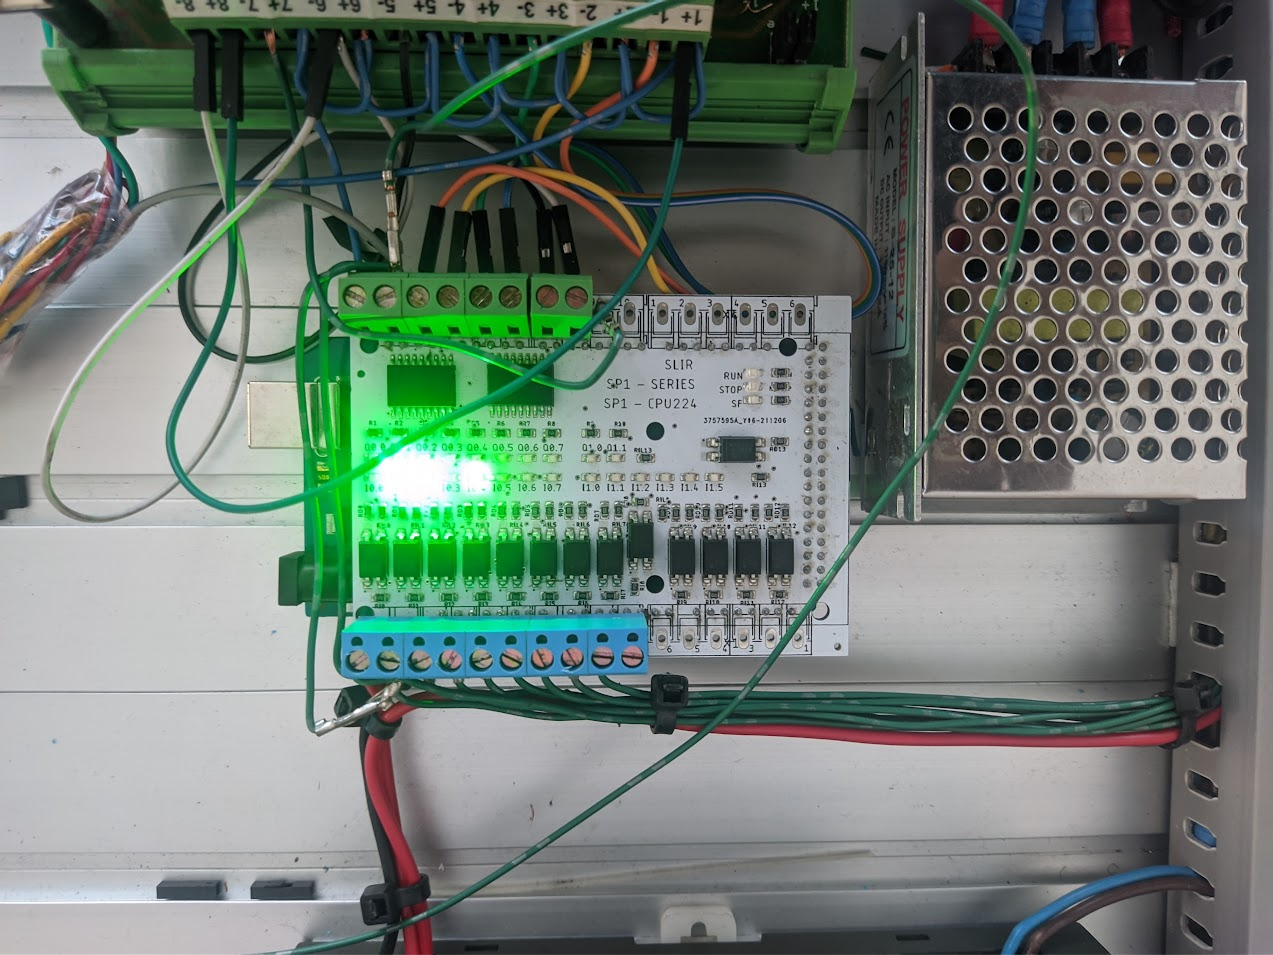
Optocoupler arduino shield to reduce EMI and
drive high power components
Water Level Adjuster using pump 
Program the System
Running Tests


Complete Setup

Penumatic Converyer belt and part picker


WEEK 2 - Intern Diary

 Day 1 - Vega Innovation

Learning  in depth - C language 

Heap memory, stack memory

Identified a faulty ESP32 using a microscope. 

Using the UCTX Serial analyzer software, Learning about CARLA- Self driving car simulator\

Finding an online simulator, https://wokwi.com/features

WEEK 1 - Intern Diary

 DAY 1 - Vega Innovation


Learned the serial communication types other than RS-232,SPI and I2C

RS-485 : Faster, than its predecessor RS232 and can have a range of 400 feet. 
Can connect about 32 devices 
Than I2C - can send more data with more speed. 

The ESP-32 has several classes
  •     S-Class                   :  Uses WIFI, Bluetooth LOW POWER .
  •     Normal Class         :  Uses WIFI, Bluetooth LOW POWER and Normal Bluetooth.  
  •     Commercial Class : Uses a proprietary OS instead of RTOS.

Installing the  ESP-IDF plugin to VScode and debugging the errors in installing it
  •  Make sure the directory name has no spaces.
  • Make sure the code has the same name as directory.
  • Code runner cannot be used in Ardiuno or ESP IDF rather its inbuilt compiler is supposed to be used which is in the left bottom of the panel

Learning TOPICS

  • NB-IOT (Narrowband-Internet of Things), 
  • LTE-M(Long Term Evolution for Machines)
  • RTOS (Real-time operating system) : 
    • Event-driven – switches tasks only when an event of higher priority needs servicing; called preemptive priority, or priority scheduling.
    • Time-sharing – switches tasks on a regular clocked interrupt, and on events; called round robin.
  • Monolithic Kernels and Micro Kernels
  • LoRA (Long Range _Communication

  • References
    https://www.contec.com/support/basic-knowledge/daq-control/serial-communicatin/

 DAY 2 - Vega Innovation


Learned the serial communication types other than RS-232,SPI and I2C

Serial data Comm

CAN - Controller Area Networks
CAN is a multi-master serial bus standard for connecting electronic control units
CAN FRAME - SIZE DEPENDS
refer wikipedia


Refer https://copperhilltech.com/blog/controller-area-network-can-bus-tutorial-message-frame-format/
https://en.wikipedia.org/wiki/CAN_bus

4 types of CAN Frames
    Remote
    Error
    Overload


UART:
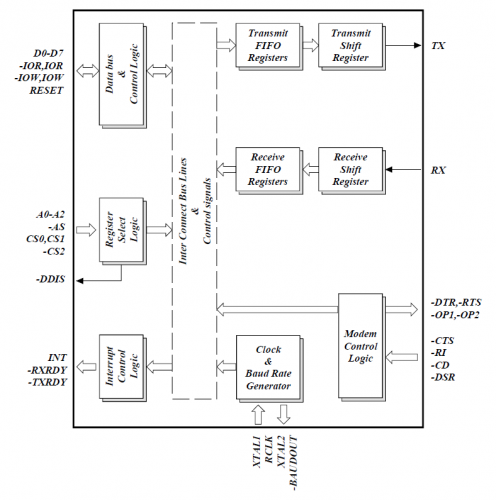
UART In works

Break Down oF Uart


RTOS: 
Real Time Operating System
There are several types
- Hard Time - Time is essential(ATMS) 
- Firm Time  - Time must be exactly strictly maintained(Airbag)
- Soft time   -Calculator

Dependant on 
    Time driven
    Event driven

In typical designs, a task has three states:

Running (executing on the CPU);
Ready (ready to be executed);
Blocked (waiting for an event, I/O for example)

ESP32
ESP32 Circuit Diagram


Using the different architectures and instruction sets in ESP32 and the use of RTOS on it.
We usually use Amazon's free RTOS but there are other alternatives like mongoos (FOSS) and QNX (Proprietary).
Each OS has inherently different advantages.

MQTT - Message Queing Telemetry Transmission (Protocol for IOT deivce communication)

Serial Communication:  https://circuitdigest.com/tutorial/serial-communication-protocols

DAY 3 - Vega Innovation


Learning more about the modules, functions and similar codes in C for the ESP32
Free() function : Removes the memory lock from melloc,calloc and other functions.
Logging in ESP32 -Uses the JTAG for it

Learning the OTA update system for the EVCU-Electrical Vehicle Controller Unit
USes the STM32 microcontroller - STM32 Cube IDE(IDE)
And the SPC570S microcontroller  - SP5 studio (IDE) and UDE (debugger)

Flash the SPC570S using JTAG debugger and using the debugger monitor the firmware using the EVCU.

Setup to flash the Jtag of the EVCU- uses ext.power supply 
And CAN to apply the OTA upadate
. 


DAY 4- Vega Innovation


Learn to create a pull request in github and merge changes.
Creating a branch so that edits can be made in the duplicate and merged finally to the ,ain branch.

Learn Code Composer Studio  and the architecture  behind programming the C2000 microcontroller(by texas Instruments)


DAY 5- Vega Innovation


Learning the C language furthur and make modifications in the giveen codes
Learn about the SMD coponents sed 
Learned abiut the different types of Capacitors 
Learnt about SIFFS,freeFS, FREERTOS functions, SD card usage in ESP32, and application of FAT in eSP

Learn that there are hardware accelerated encryption and an ULP-(ultra low power) coprocessor
Learnt about the ESP 32 in depth and the different variants in it.

Learnt to fing the MAC address in the ESP32